I teach robot arms to do tasks on their own from human demonstrations, and build the testing that says honestly whether they work.
92%
pick-and-place success, 50 trials on a real arm at the trained cube position
2.49 cm
average distance from target on successful placements
49,633
frames of robot demonstrations published as an open dataset, across 50 episodes
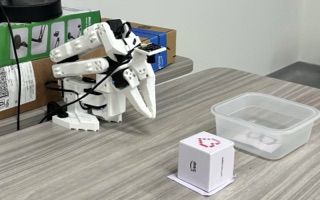
Taught an SO-101 robot arm to pick up a cube and place it in a bowl on its own: 46 of 50 real trials succeeded, 2.49 cm from target on average, using a transformer policy (ACT) trained on 50 human demonstrations.
Kept a checkpoint with 67% higher action error from being used by choosing checkpoints on task accuracy rather than training loss, and ruled a larger vision-language-action model out of real-time control at 251 ms against 18 ms a decision.
Built a test harness that runs 100 trials with nobody watching: it resets the arm, recovers from crashes, and logs why each miss happened. That trace put every failure on perception, and found a motor firmware bug that reassigned device IDs.
Stated up front: the 92% is at the one cube position all 50 demonstrations used. Fifty trials at measured offsets, which will show whether the policy reads the scene or memorised a motion, are not in yet.